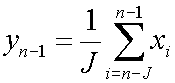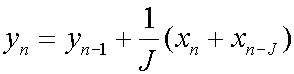1. Digital PID controller
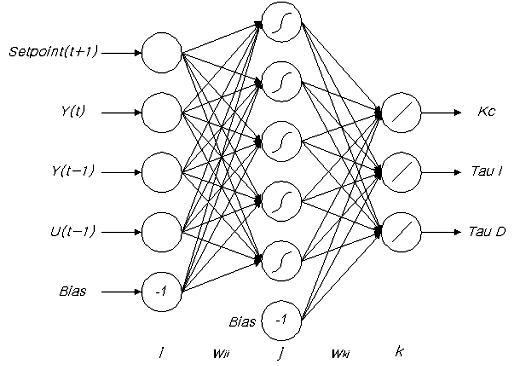
2. Neural Network
3. Neuro PID controller의 전체 구조
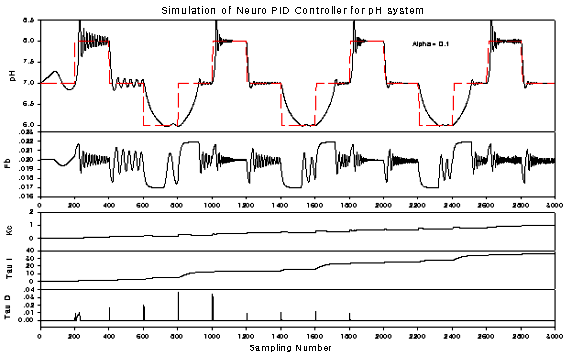
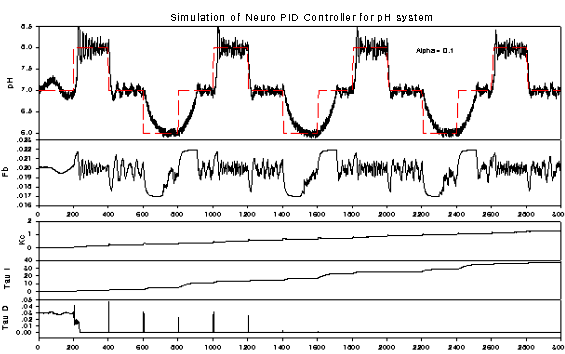
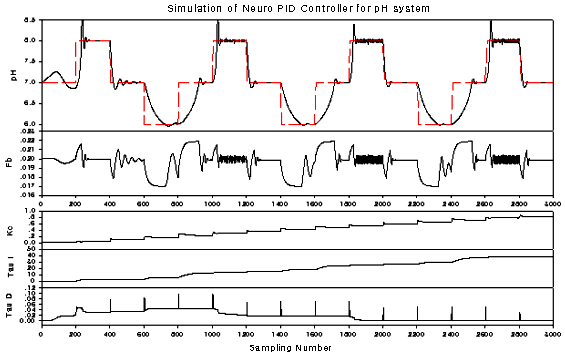
4. Simulation 결과 (No Filter)
5. Digital filters
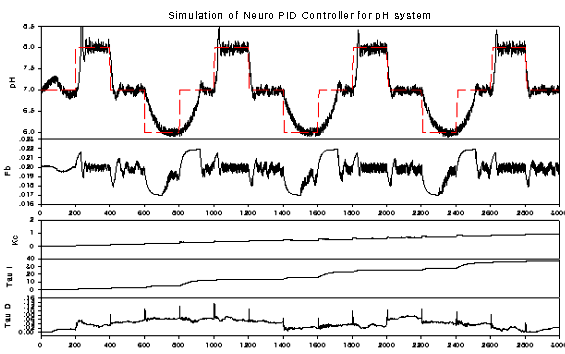
6. Simulation 결과 (Filter 설치시)
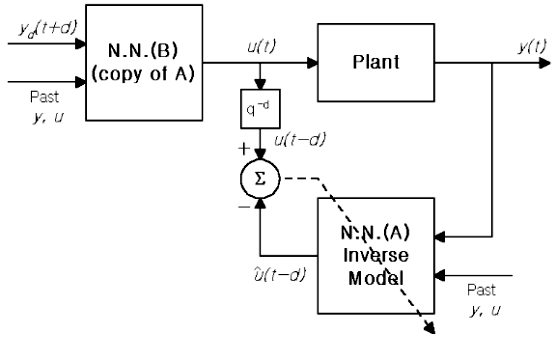
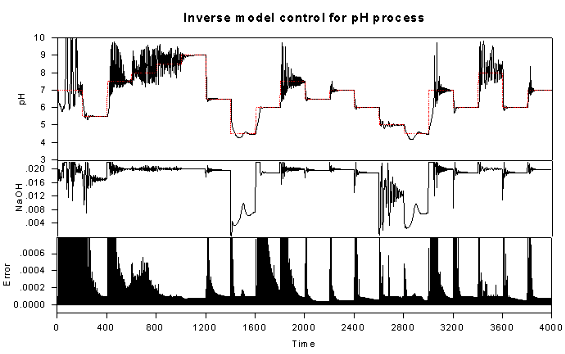
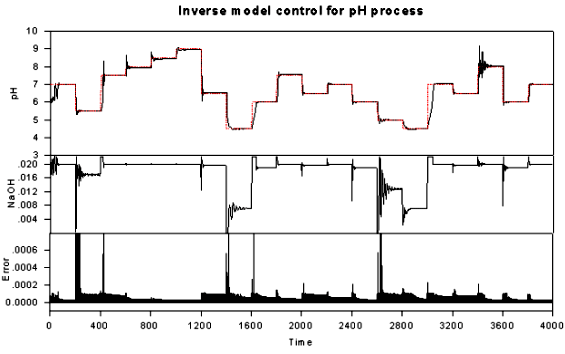
7. INVERSE MODEL CONTROLLER와 비교
1. Structure
,
where,
: constant
2. Learnning Rule (Error-back-propagation)
- 일반적인 Error-back-propagation 알고리즘
-제어기에 사용된 Error-back-propagation 알고리즘
3. Algorithm
- Step 0 : Weight 초기화(-0.5∼0.5)
- Step 1 : Weight 수정
- Step 2 :
이면 goto Step 1
1. Exponential filter
: measured
: filtered
- Use of backward difference approximation
for analog filter
: filter constant ⇒
: Weighted summation!
⇒ single exponential smoothing
: No filtering ()
: measurement is ignored ()
2. Moving average filter
J: moving window size
(recursive form) : low pass filter
1. 제어기 출력에 Exponential filter 설치
- Noise가 없을시
- Noise가 들어갈 시(±0.1)
2. 제어기 출력에 Moving average filter 설치
7. Inverse model controller와 비교
- 1번째 학습
- 2번째 학습
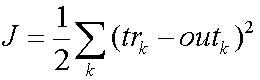
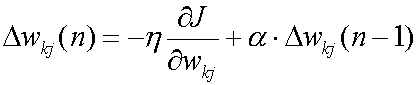
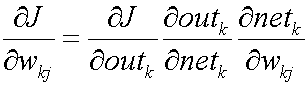
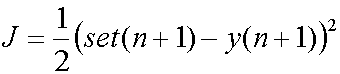
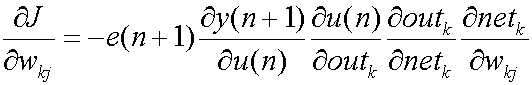
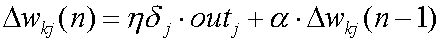
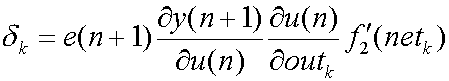
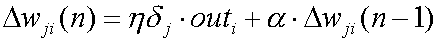
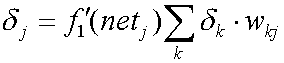
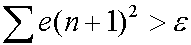 이면 goto Step 1



 PID Controller for pH System
 ,

 ,

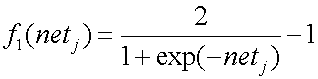

 : constant
 : measured
 : filtered
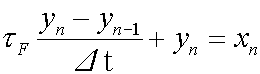
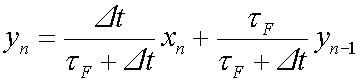
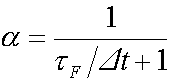 : filter constant ⇒
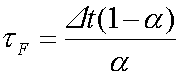
 : Weighted summation!
 : No filtering (
 )
 : measurement is ignored (
 )
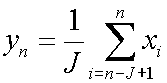 J: moving window size